Real robot jobs, rerun in physics. Every attempt.
A real Unitree G1 recording, its place rebuilt as a MuJoCo 4.0.1 twin, the same job rerun with the robot balancing on its own controller (AMO or GR00T), then measured. Failures stay on this page.
Drinks into a fridge drawer
Real recording: G1_WBT_Inspire_Put_Drinks_Into_Fridge_v0, episode 0
The bottle ends in the drawer and the drawer shuts; no fall in the 31 s run. Disclosed: the robot closes the drawer with its hand, and the last part of the travel is a soft-close spring on the slide.
Two drinks from a shelf into a basket
Real recording: G1_WBT_Inspire_Pick_Up_Drinks_v0, episode 0
Both bottles held by finger friction alone and released inside the basket; right-wrist error 2.2 cm (median); deepest unintended robot–scene contact 2.0 mm. GR00T dropped the second bottle. Disclosed: the basket is fixed to the left hand (closed on the handle in the recording); the second bottle moved 3 cm closer to fit the physical reach.
Vegetables into a basket
Real recording: G1_WBT_Inspire_Put_Vegetables_Into_Basket_v0, episode 0
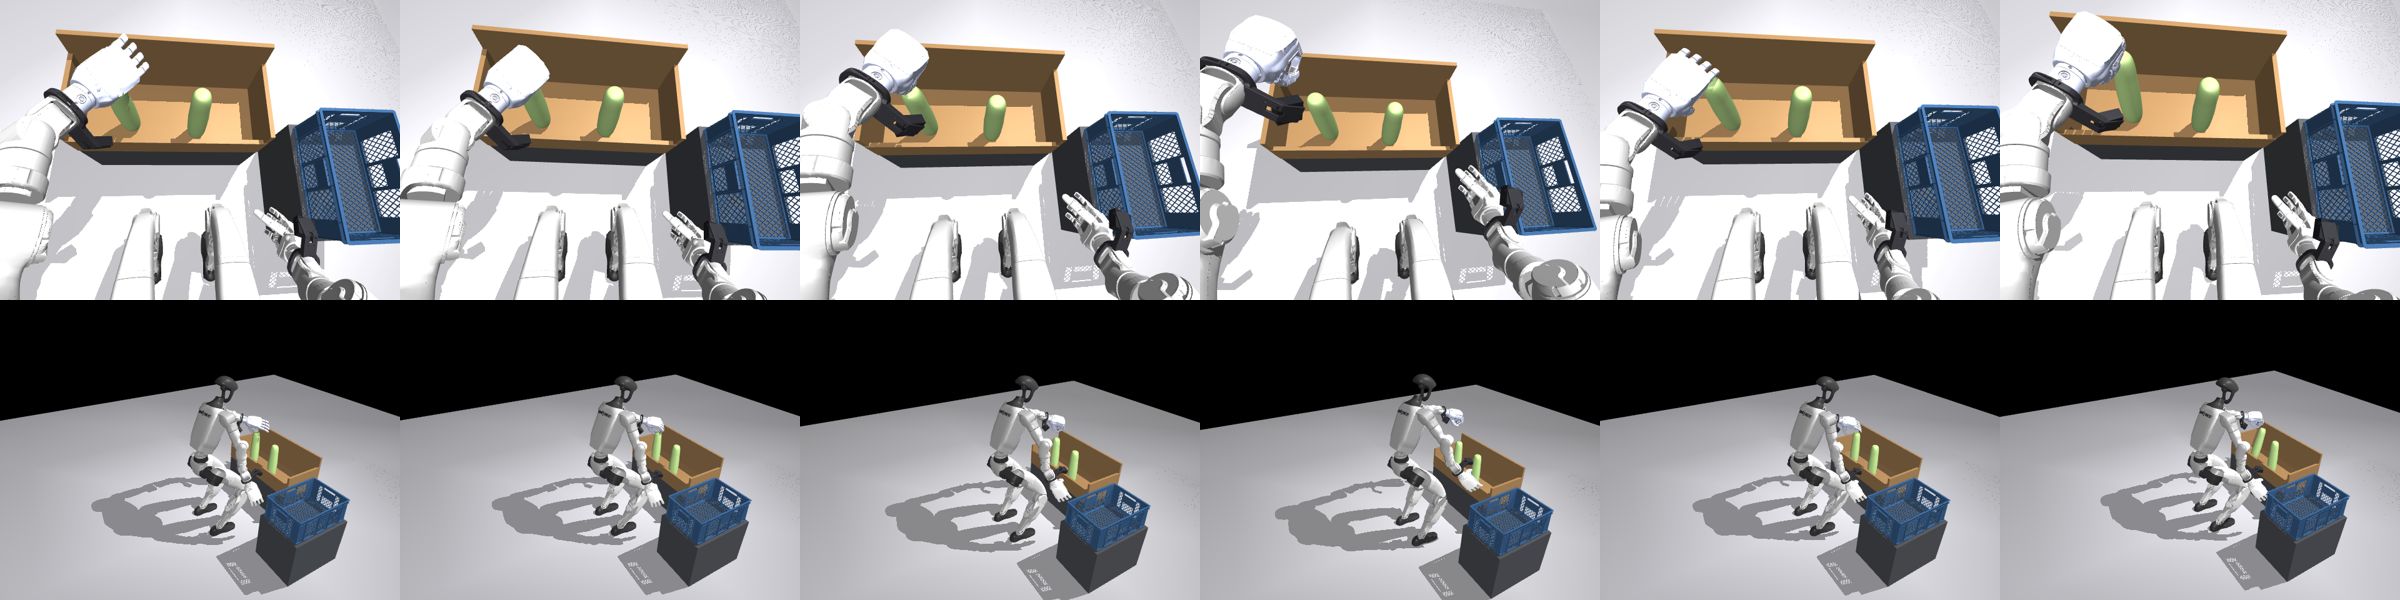
Neither AMO nor GR00T grasps the cabbage; the robot does not fall. During the crouch and 30° lean the wrist is still about 4 cm off the recording, and a top grasp on a standing 7 cm cabbage needs 1–2 cm, so the hand sweeps in and knocks it over.
Tidy the room: a crumpled cloth into a tray
Real recording: G1_WBT_Inspire_Clean_The_Living_Room, episode 0
A rigid crumpled bundle is pushed, not pinched. Key finding for every card: the torso command has to follow the recorded torso tilt in the world, not the waist joint; with that, wrist error dropped from 3.8–6.5 cm to 1.0–2.5 cm (median).
A 30 g simulation-ready cloth (soft shell, folds on itself) starts as a 7 cm pile; AMO puts all of it in the tray (target ≥ 50 %). GR00T does not grasp. Disclosed: while the recorded hand is closed, cloth points within 4.5 cm of the grip are held to it.
Pour a drink at a dispenser
Real recording: RoboCOIN Unitree_G1edu_u3_pour_drink, episode 665
The dataset has no leg recording and the hand sits at another angle on the wrist: the recorded wrist matches our model exactly, yet the hand grips from below where the real one grips from the side. Restarts only with a pour dataset in the same format as cards 1–4.
A plate from the drainer into the dishwasher
Real recording: G1_WBT_Brainco_Collect_Plates_Into_Dishwasher, episode 0 (BrainCo fingers mapped onto our Inspire hand)
A side view showed the plate lying flat on top of the rack, not in it. An earlier "passed" came from a head-camera check and a target box that was too tall; we corrected it.
Another simulation-ready dishwasher (three sliding racks): both AMO and GR00T put the plate into the middle basket in all 3 repeats each, checked from the side.
Upper rack, plate held by a friction-only rim pinch (no weld): GR00T 3/3, no fall, plate upright in the rack; AMO 0/3 (base drift 15.8 cm). Disclosed: robot stands 18 cm closer, plate carried upright on its own path, door non-colliding.
Clothes into a laundry basket
Real recording: G1_WBT_Inspire_Put_Clothes_Into_Basket
Cloth task; after card 4’s cloth method.
Make the bed
Real recording: Unitree G1 open dataset (BrainCo hand)
Large cloth and BrainCo source hand; the hardest card, left for last.
Real footage: Unitree Robotics and RoboCOIN open datasets on Hugging Face (Apache-2.0). Physics: MuJoCo 4.0.1; robot model Unitree G1 29-DoF with Inspire hands (MJCF). Balance controllers: AMO (Apache-2.0) and GR00T WBC (NVIDIA Open Model License).
Hospitality Humanoid Intelligence
Forenly AI turns real scenes into simulation where humanoids learn their skills — then transfers them onto the machine.